About me
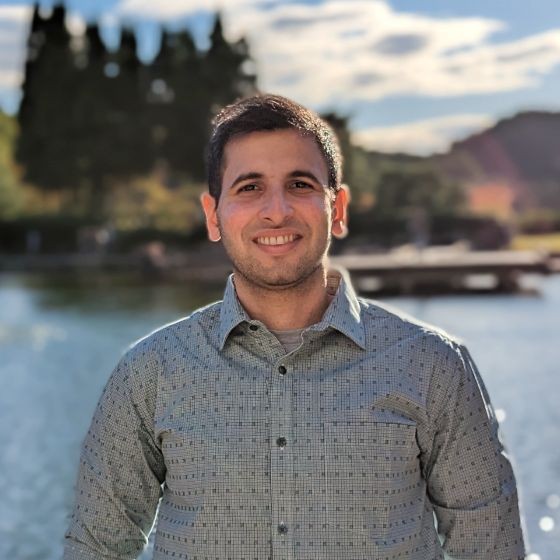
Hi! I am Akshay Hinduja, a Software Engineer for Embedded Data and Algorithms in the Software Engineering - Embedded group at MBARI, the Monterey Bay Aquarium Research Institute, in Moss Landing, CA.
I completed my PhD in Robotics from the Department of Mechanical Engineering at Carnegie Mellon University in July 2024, advised by Prof. Michael Kaess at the Robot Perception Lab. I also obtained my Master’s from CMU, advised by Prof. Kenji Shimada.
I build perception and SLAM systems for underwater robots. My work covers embedded vision and AI that runs on the vehicles, drivers for cameras and acoustic sensors, and localization in GPS-denied environments. You can read about my engineering work on the Projects page and my papers on the Publications page.
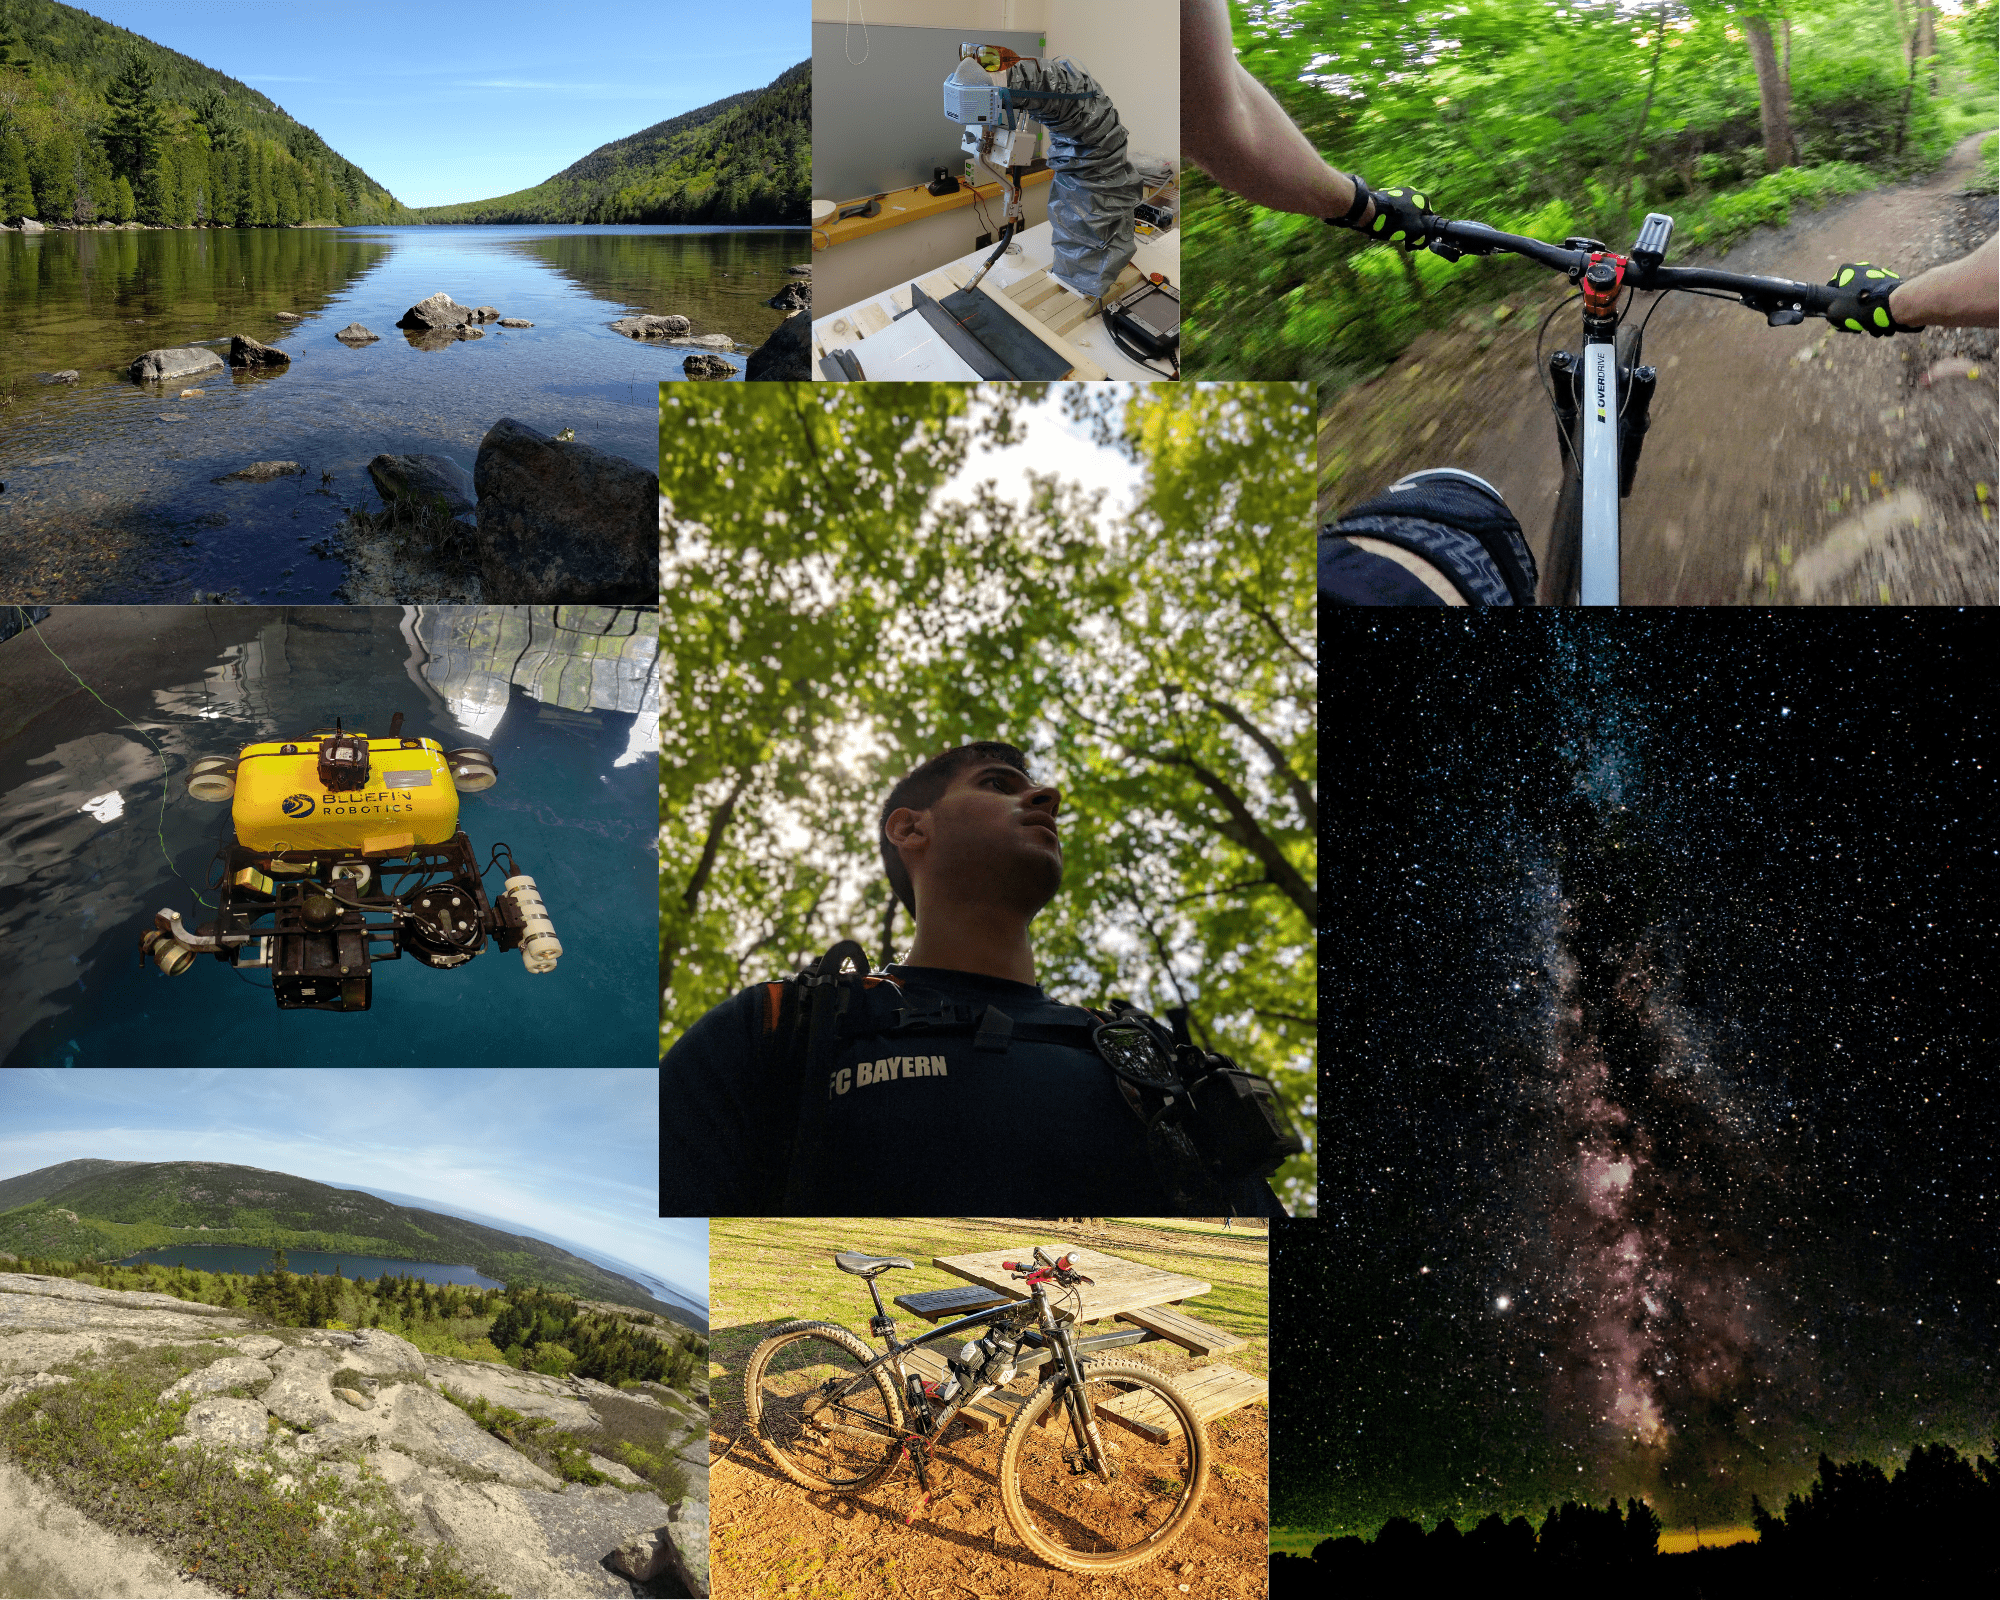
Apart from getting robots to do cool things, I enjoy spending time with my wife and daughter, taking her out on adventures whether on foot or on my mountain bike!
News
2024
-
Joined MBARI as a Software Engineer for Embedded Data and Algorithms in the Software Engineering - Embedded group (July 2024).
-
Completed my PhD at Carnegie Mellon University with the thesis “Underwater Localization and Mapping for Cost-Effective Robots” (July 2024).
-
Our paper, “Multi-Radar Inertial Odometry for 3D State Estimation using mmWave Imaging Radar”, has been accepted for ICRA 2024!
-
Our paper, “SONIC: Sonar Image Correspondence using Pose Supervised Learning for Imaging Sonars”, has been accepted for ICRA 2024!
-
Reviewing for IEEE Intl. Conf. on Robotics and Automation (ICRA) 2024
2023
-
Presenting a poster for our work “SONIC: Sonar Image Correspondence using Pose Supervised Learning for Imaging Sonars” at IROS 2023, Detroit. We are presenting at two workshops, 2nd Advanced Marine Robotics and Closing the Loop on Localization.
-
Reviewing for IEEE Transactions on Robotics (T-RO)
-
Reviewing for IEEE Journal of Ocean Engineering (JOE)
-
Presented my thesis proposal title “Underwater Localization and Mapping for Cost-Effective Robots”. Got a couple of exciting projects in line to improve feature-based SLAM using imaging sonars!
-
Reviewing for IEEE Transactions on Robotics (T-RO).
-
Our paper, “Conditional GANs for Sonar Image Filtering with Applications to Underwater Occupancy Mapping”, has been accepted for ICRA 2023!.
-
Reviewing for IEEE Transactions on Robotics (T-RO).
2022
-
Attending IROS 2022 in Kyoto, Japan!.
-
Our paper, “Acoustic Localization and Communication Using a MEMS Microphone for Low-cost and Low-power Bio-inspired Underwater Robots”, has been accepted for IROS 2022!.
-
Reviewing for IEEE Transactions on Robotics (T-RO).
-
Reviewing for IEEE Robotics and Automation Letters(RA-L).
-
Won the Milton Shaw Ph.D. research award from the department of Mechanical Engineering!
-
Head TA for 24-787 Machine Learning and Artificial Intelligence for Engineers.
2020
-
Head TA for 24-370 Engineering Design I: Methods and Skills.
-
Completed my subject and research PhD qualifiying exams!.
2019
-
Attending IROS 2019 at Macao, China!.
-
Our paper, “Degeneracy-Aware Factors with Applications to Underwater SLAM”, has been accepted for IROS 2019!.
-
Our paper, “Designing a Mobility Solution for Fully Autonomous Welding of Double-Hull Blocks”, has been accepted by the ASME Journal of Mechanisms and Robotics!.
2018
-
Started PhD program in the Mechanical Engineering department, advised by Prof. Michael Kaess at the Robotics Institute.
-
Our paper, “Feature-based SLAM for imaging sonar with under-constrained landmarks”, has been accepted for ICRA 2018!.
2017
-
Promoted to Systems Engineer at RPL.
-
Joined Robot Perception Lab(RPL), Robotics Institute as Extern.
-
Completed my Master’s in Mechanical Engineering, working on NDT based lidar odometry of a welding robot, advised by Prof. Kenji Shimada.