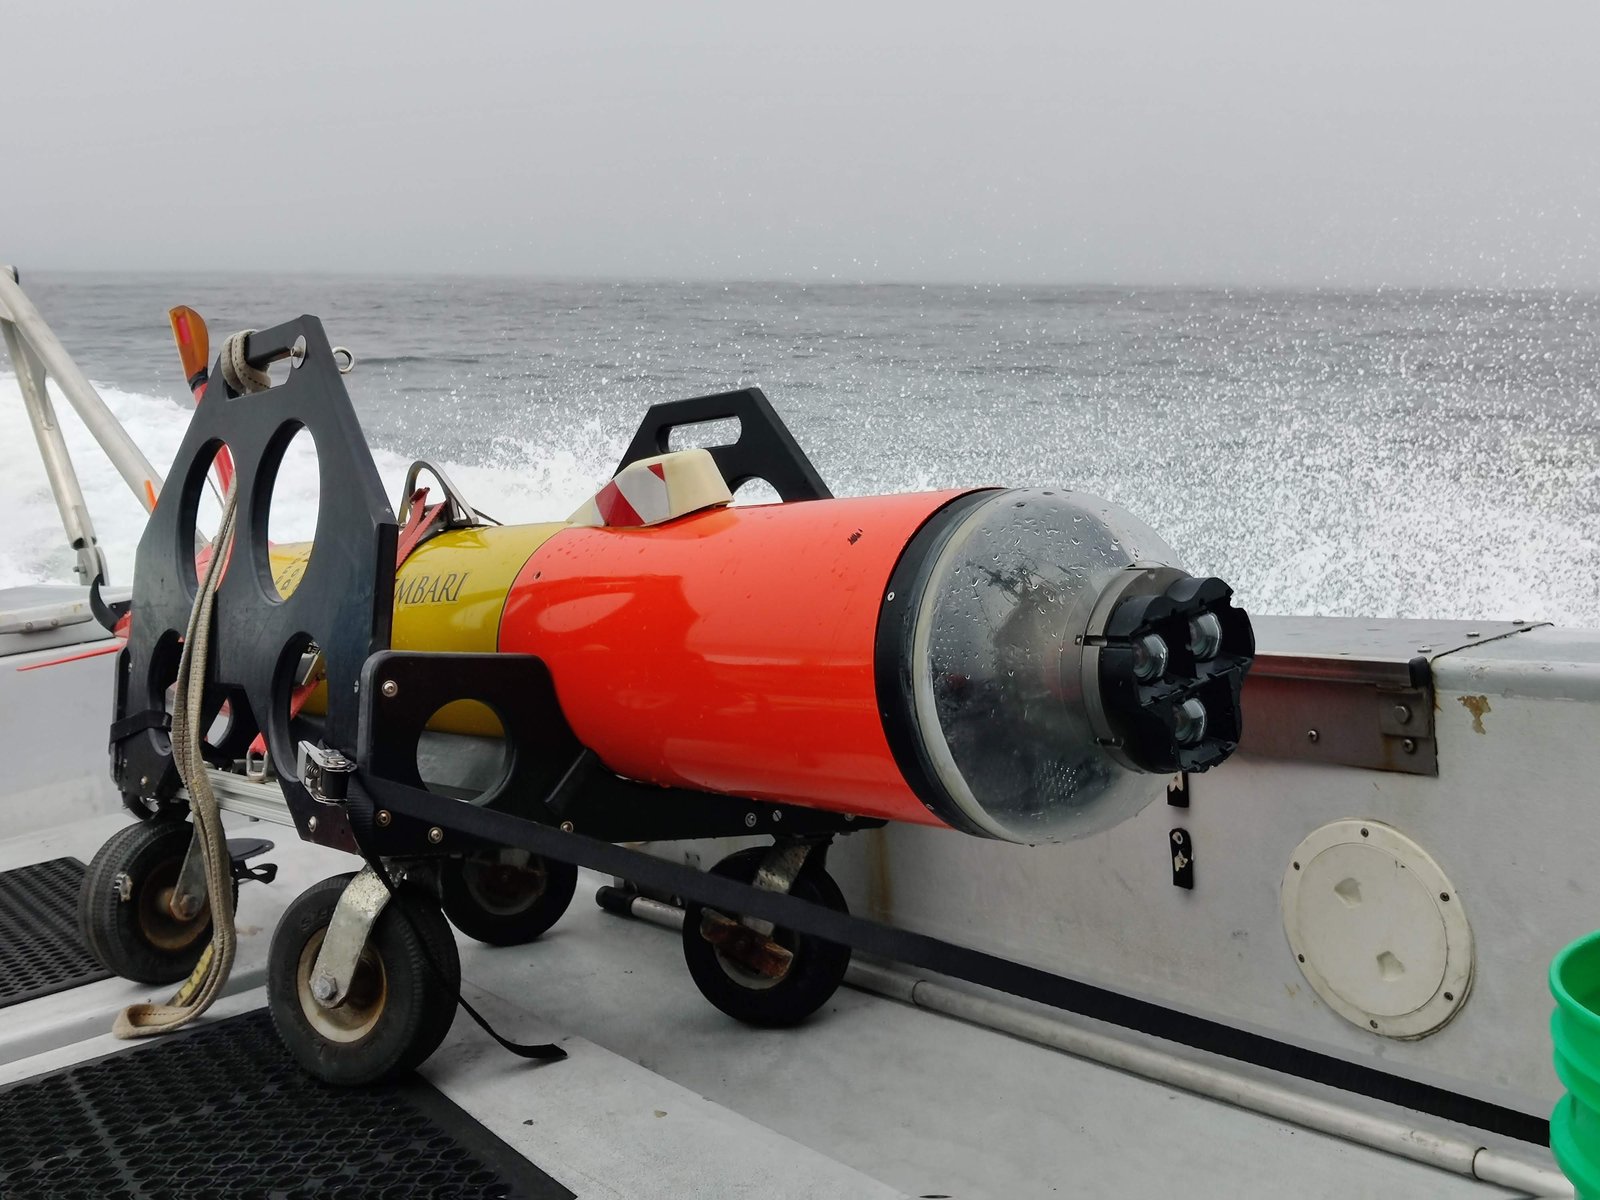
On-vehicle perception for MBARI's autonomous underwater vehicles: multicamera drivers for edge computers, embedded machine learning for tasks such as tracking marine animals, and the link that lets perception drive vehicle behavior.
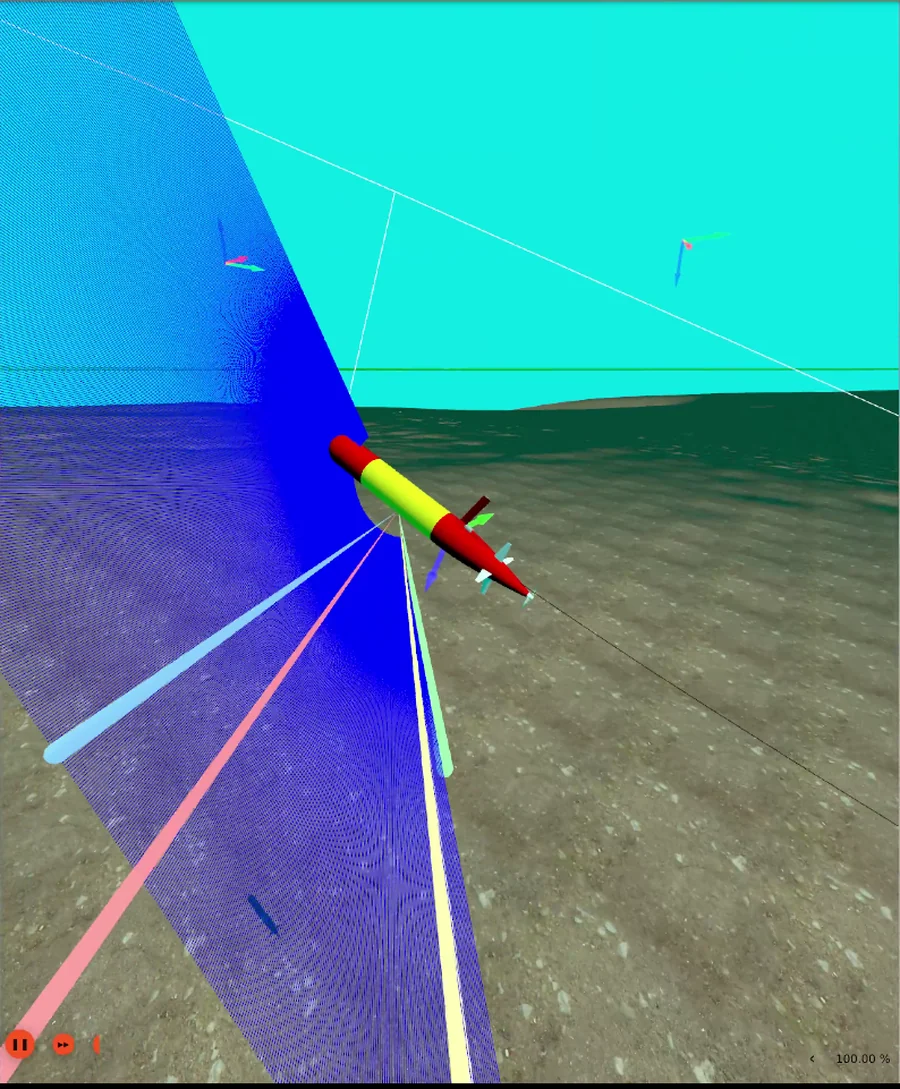
Open-source, containerized ROS 2 and RViz tooling that replays vehicle dive logs as a 3D reconstruction of the navigation, vehicle state and science data.
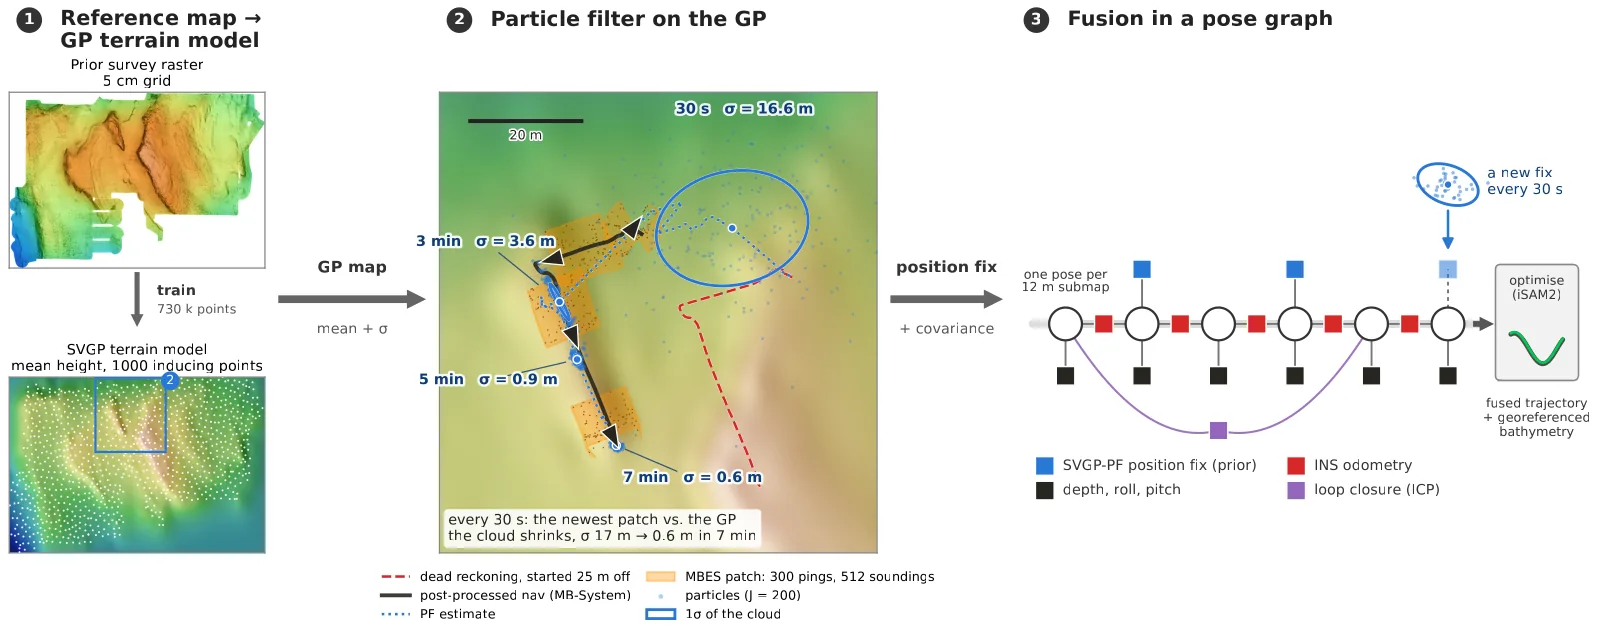
Submap-based localization for autonomous underwater vehicles in low-altitude surveys, fusing particle filter updates with a pose graph to produce geo-localized 3D maps.